Jupiter-1S Inspection Robot
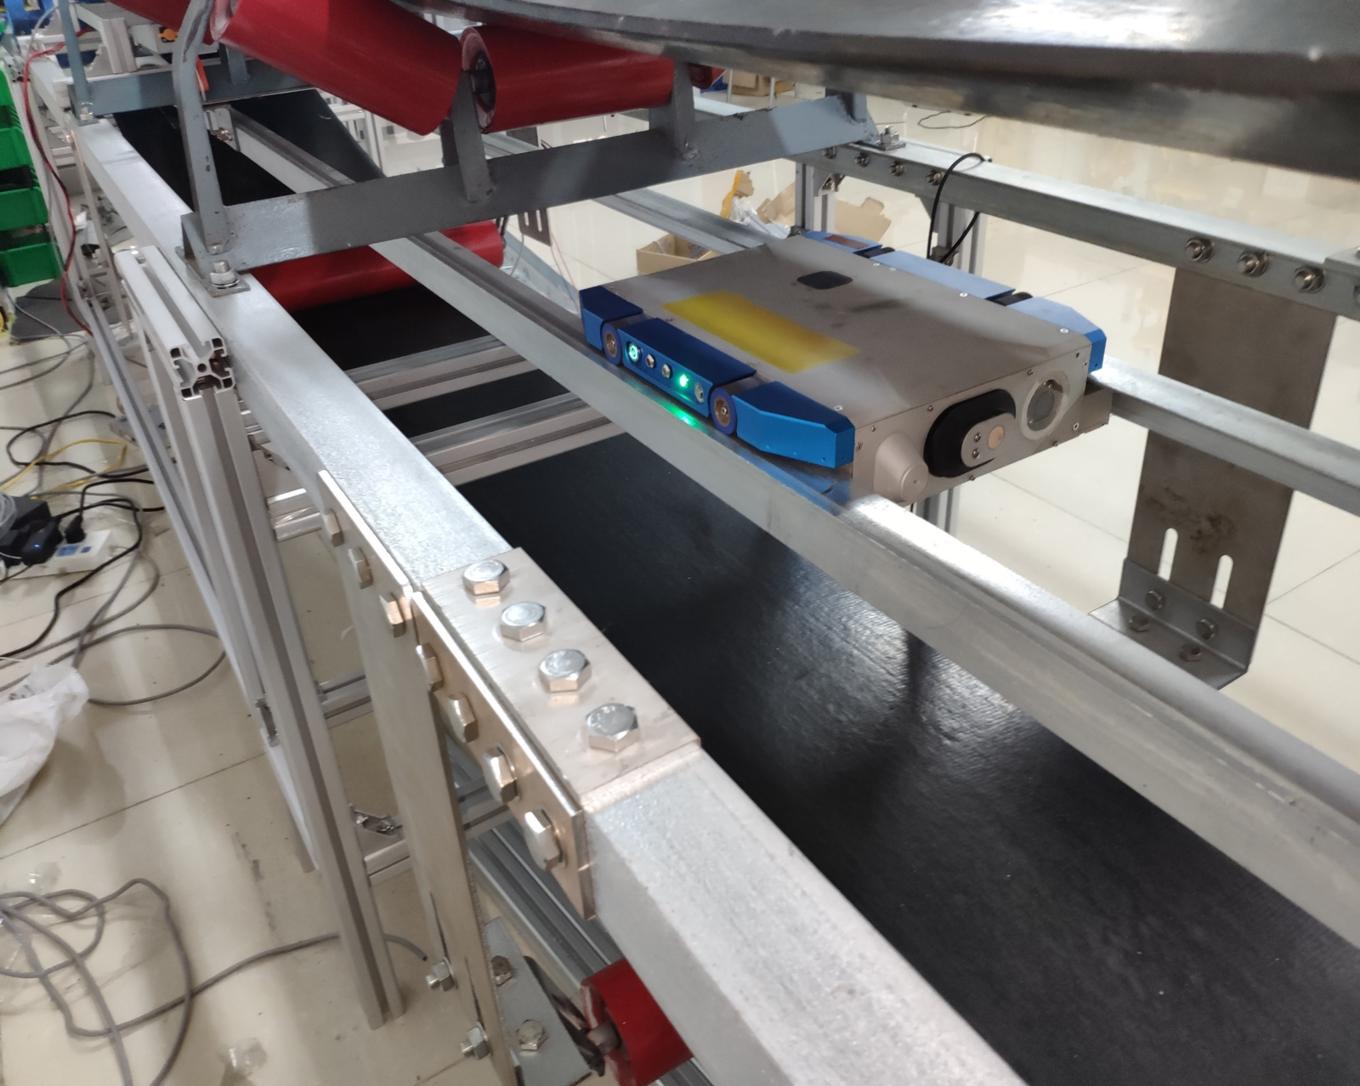
The Jupiter-1S inspection system is installed between the upper and lower conveyor belts. It monitors roller temperature and noise, and provides video observation of the belt surface.
The system combines the inspection robot, wireless network, operating platform and charging point. It records operating conditions, displays trends and generates exception alarms to support maintenance.
Listed robot specifications: weight 7 kg; protection class IP66; dimensions 345 × 280 × 70 mm; permissible gradient 30°; running speed 0.3 m/s; running mileage 5 km; double No. 4 angle-steel track.
The system also supports self-localization, autonomous navigation, self-recharging and obstacle avoidance. The final installation requires review of conveyor access and project conditions.
- 01 Temperature, noise and video inspection
- 02 Operating trends and exception alarms
- 03 IP66 robot with autonomous charging
Product Overview
-
Jupiter-1S Inspection Robot
The Jupiter-1S inspection system is installed between the upper and lower conveyor belts. The system supports roller temperature and noise inspection and video observation of the belt surface.
Technical Details
The Jupiter-1S inspection system is installed between the upper and lower conveyor belts. It monitors roller temperature and noise, and provides video observation of the belt surface.
The system combines the inspection robot, wireless network, operating platform and charging point. It records operating conditions, displays trends and generates exception alarms to support maintenance.
Listed robot specifications: weight 7 kg; protection class IP66; dimensions 345 × 280 × 70 mm; permissible gradient 30°; running speed 0.3 m/s; running mileage 5 km; double No. 4 angle-steel track.
The system also supports self-localization, autonomous navigation, self-recharging and obstacle avoidance. The final installation requires review of conveyor access and project conditions.
Related Conveyor Products
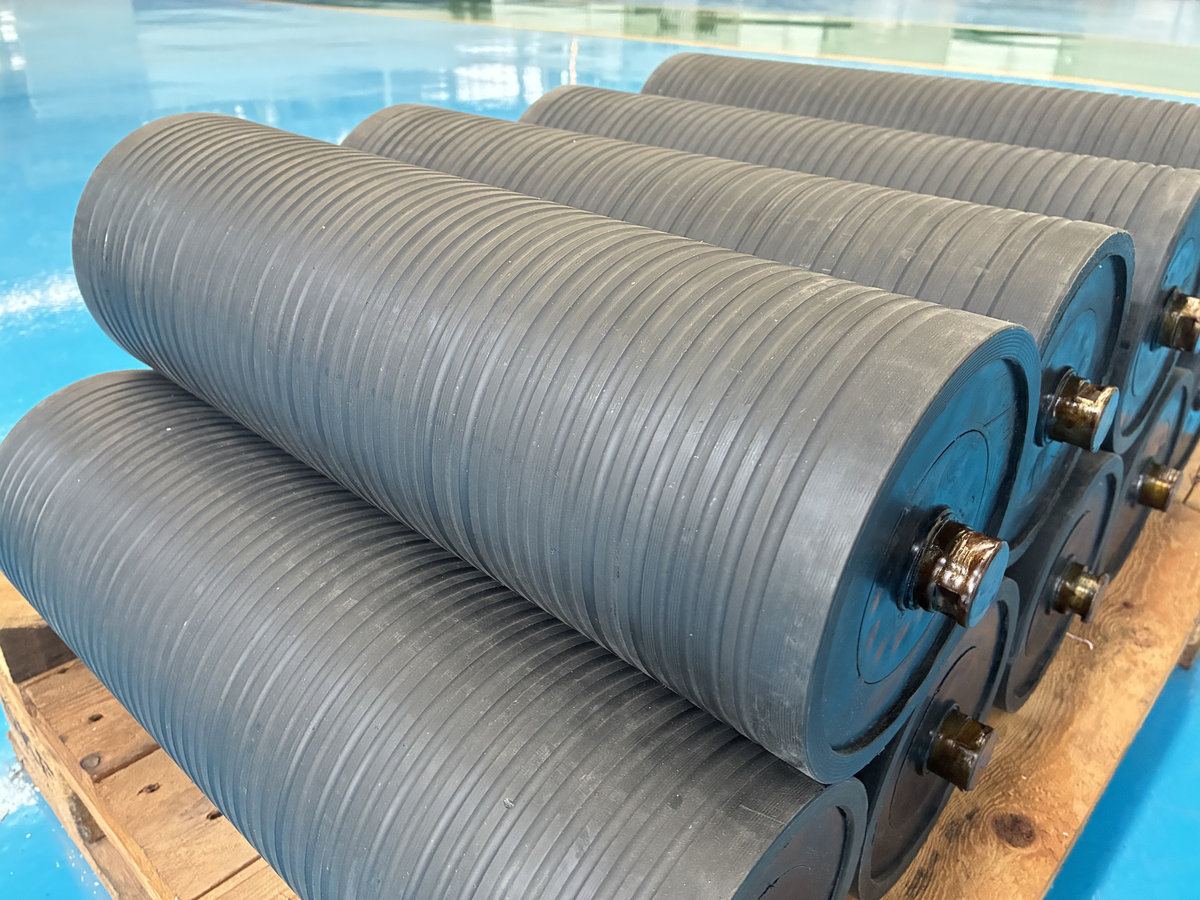
Polymer roller / Nonmetal Low-Noise Idlers
Impact Idler Assemblies
Long-Distance Belt Conveyors
Tubular Conveyor / Pipe Conveyor
Conveyor Control and Protection Systems
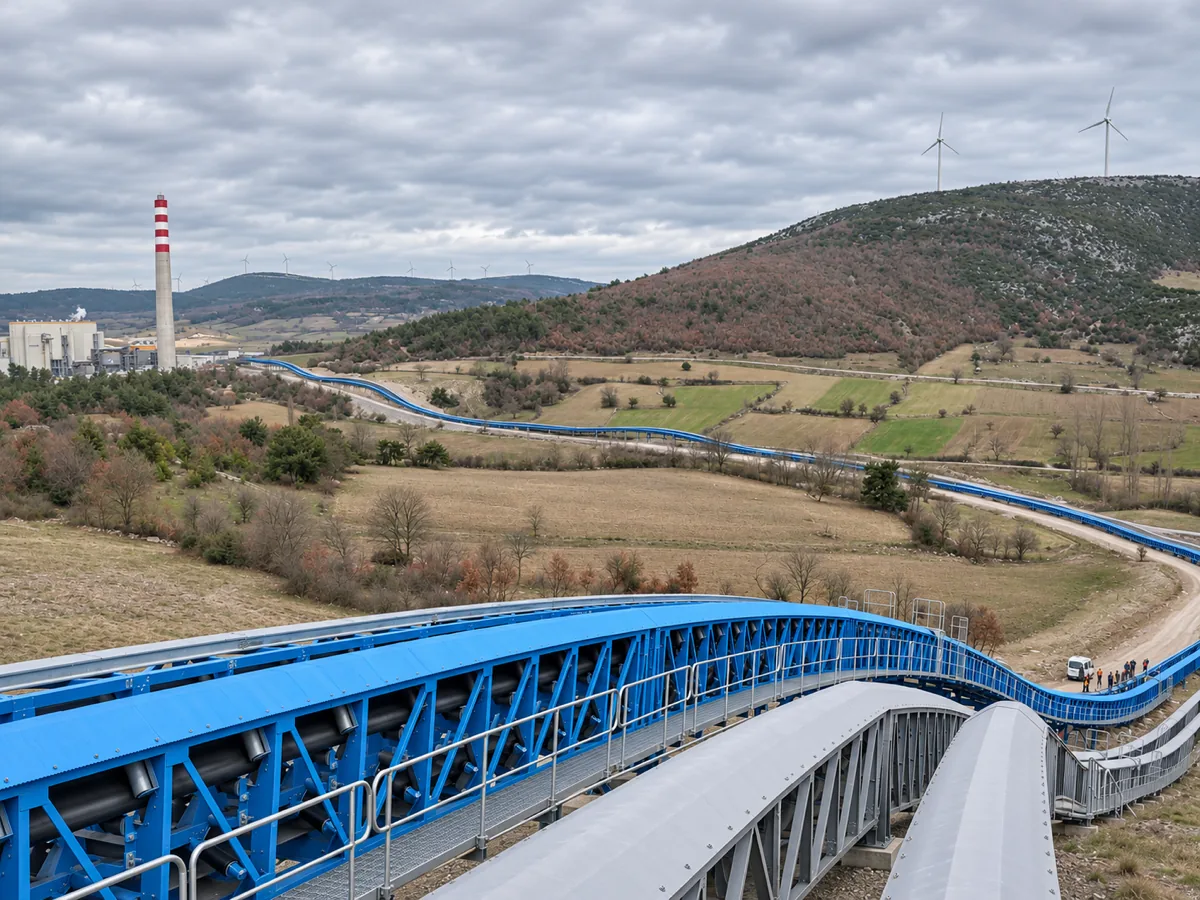
Long-Distance Curved Belt Conveyors
Conveyor Knowledge
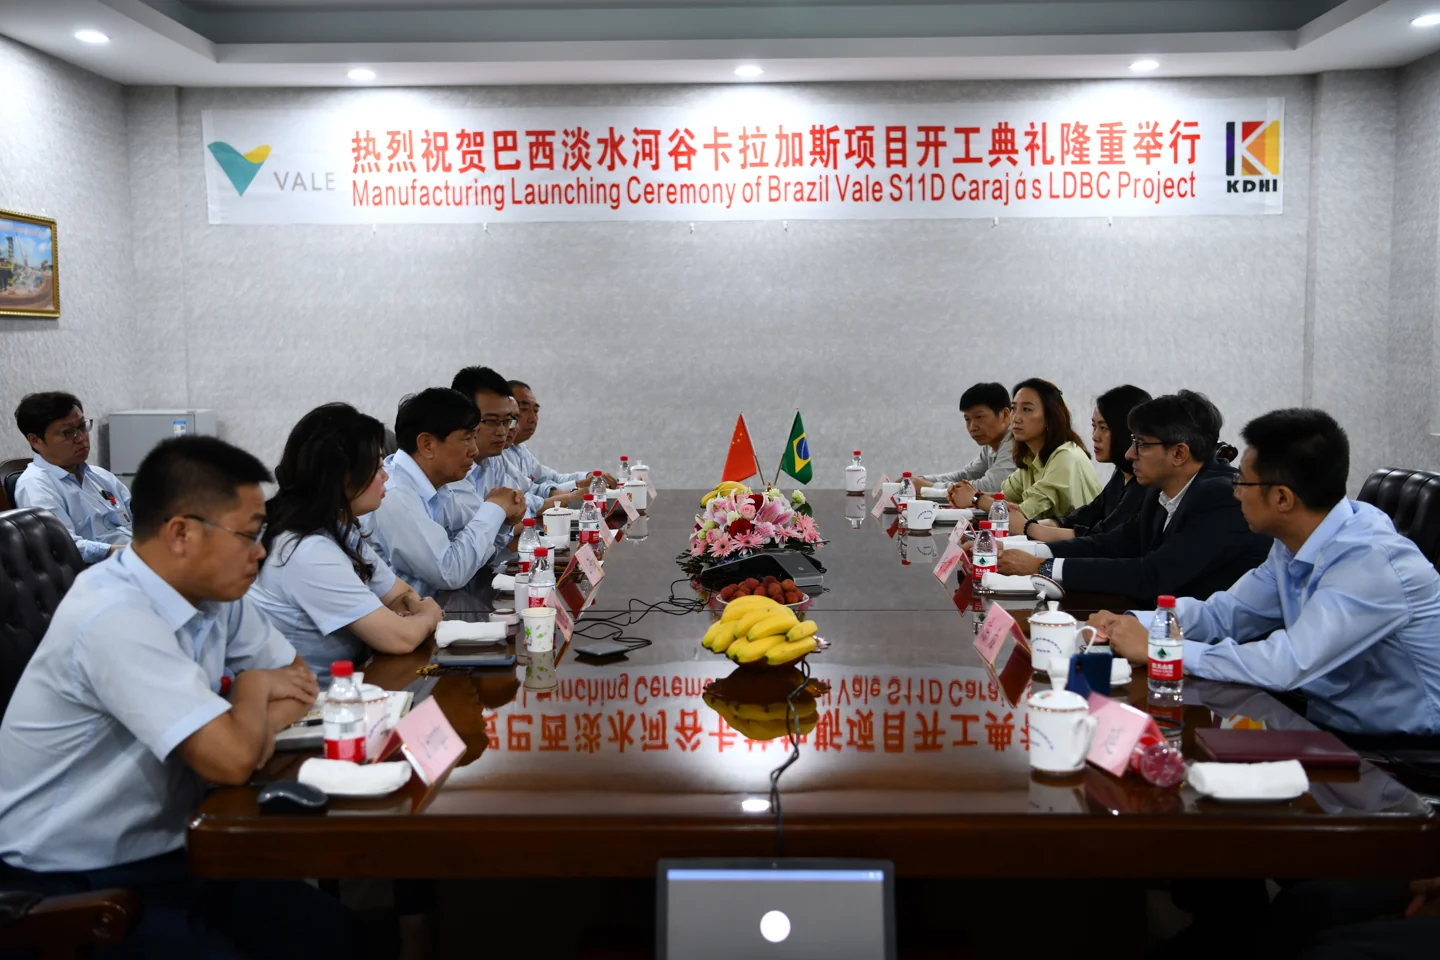
Manufacturing Launching Ceremony of Brazil Vale S11D Carajos LDBC Project
Nov 10, 2026
KDHI Company News and Updates
Nov 10, 2026

Quality Checks in Conveyor Manufacturing
Apr 22, 2026
Engineering & Support